Marketplace
The examples from Ordinate 2D, and scenes, parts, materials and scripts made by its users. All free: open one in the studio with one click.
From Ordinate 2D ✓
Script
PD control: move a cart to a target
F = kp·(target − x) − kd·v moves a cart to four targets; the console gives each move's overshoot and settling time.
Script
PID: balance a pole on a cart
An inverted pendulum on a cart held up by a PID controller written in the script.
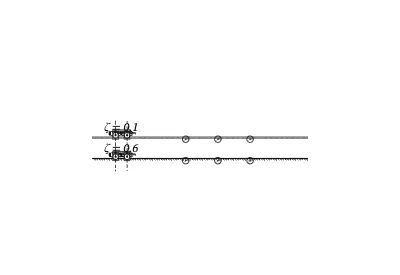 Cars over Bumps: Suspension
Two cars on springs drive over the same bumps. Weak dampers (ζ = 0.1) keep bouncing; ζ = 0.6 settles after one swing.
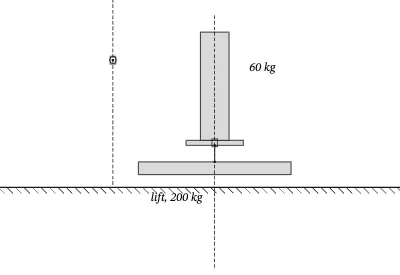 Apparent Weight in a Lift
A passenger on a scale in a lift that goes up and down: the scale reads N = m(g + a), more while the lift speeds up going up (or brakes going down), less the other way round.
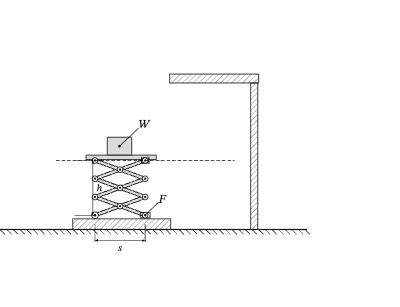 Scissor Lift
Three stages of crossed bars lift a 40 kg crate as a driven roller closes the feet: the platform stands n √(L² − s²) high, and the roller's push, g (n M + n² m) cot θ by virtual work, is largest when the lift is low.
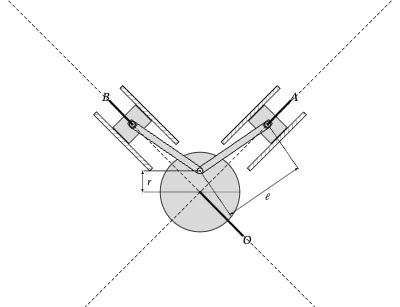 V-Twin Engine
Two pistons 90° apart on one crank pin: each stroke follows s = r cos δ + √(l² − r² sin² δ), and the momentum of the moving parts turns in a nearly steady circle.
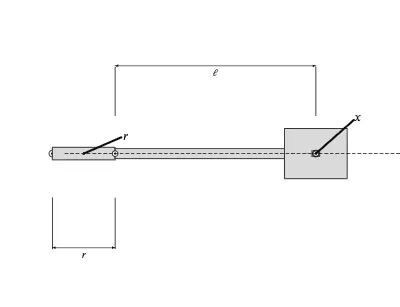 Slider-Crank
A motor turns a crank; a connecting rod drives a piston along its cylinder: x = r cos φ + √(l² − r² sin² φ).
Cars over Bumps: Suspension
Two cars on springs drive over the same bumps. Weak dampers (ζ = 0.1) keep bouncing; ζ = 0.6 settles after one swing.
Apparent Weight in a Lift
A passenger on a scale in a lift that goes up and down: the scale reads N = m(g + a), more while the lift speeds up going up (or brakes going down), less the other way round.
Scissor Lift
Three stages of crossed bars lift a 40 kg crate as a driven roller closes the feet: the platform stands n √(L² − s²) high, and the roller's push, g (n M + n² m) cot θ by virtual work, is largest when the lift is low.
V-Twin Engine
Two pistons 90° apart on one crank pin: each stroke follows s = r cos δ + √(l² − r² sin² δ), and the momentum of the moving parts turns in a nearly steady circle.
Slider-Crank
A motor turns a crank; a connecting rod drives a piston along its cylinder: x = r cos φ + √(l² − r² sin² φ).
From the community
Nothing here yet that matches. Publish your own from the studio: My Assets → Publish.